Project
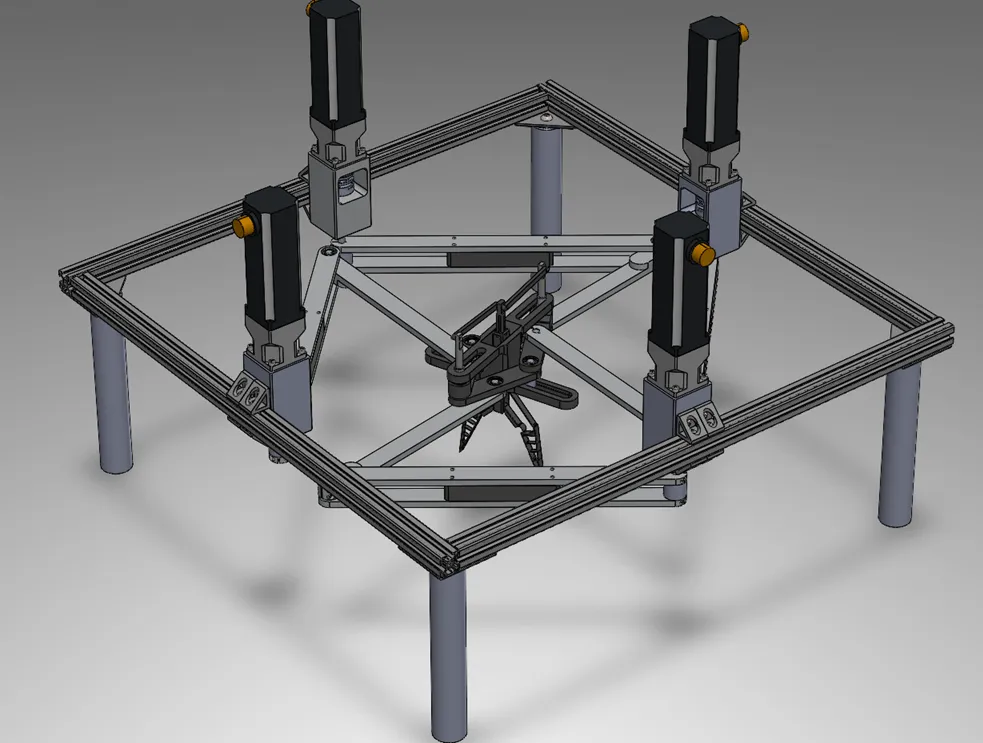
Reconfigurable Parallel Robot with Bistable Gripper
Technology
SolidWorksParallel RoboticsRobot KinematicsDynamic ModelingMATLABSimscapeDigital TwinMechanical DesignCompliant MechanismsSoft RoboticsBistable MechanismFin Ray Effect3D PrintingSLS ManufacturingPrototype Development
Year
2024
Context
Personal robotics project to build a 4-DOF reconfigurable parallel robot for Pick & Place applications that needed to handle objects of different geometries without swapping end-effectors.
Constraints
The gripper had to lock and unlock mechanically, without external sensors or actuators, and adapt to complex shapes while being manufacturable by SLS 3D printing as a monolithic part.
My Role
Mechanical design and complete kinematic modeling of the robotic system (forward and inverse kinematics, MGD/MGI), singularity study, and dynamic behavior validation, plus the sizing and workspace study of the bistable gripper.