Project
Robotic Fastener Quality System — AUTOCLIP Line
Technology
Year
2022
Context
Industrial optimization project on Fuba's AUTOCLIP production line, aiming to fix an unreliable robotic fastening process on a 6-axis robot used for door panel assembly.
Constraints
The fix had to compensate for positioning errors up to ±1 mm using the existing 6-axis robot and fastening hardware, and had to be validated across multiple production workstations, not just a single test cell.
My Role
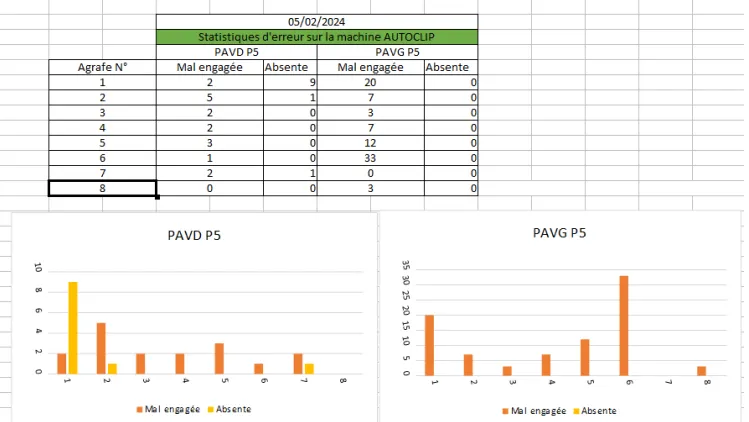
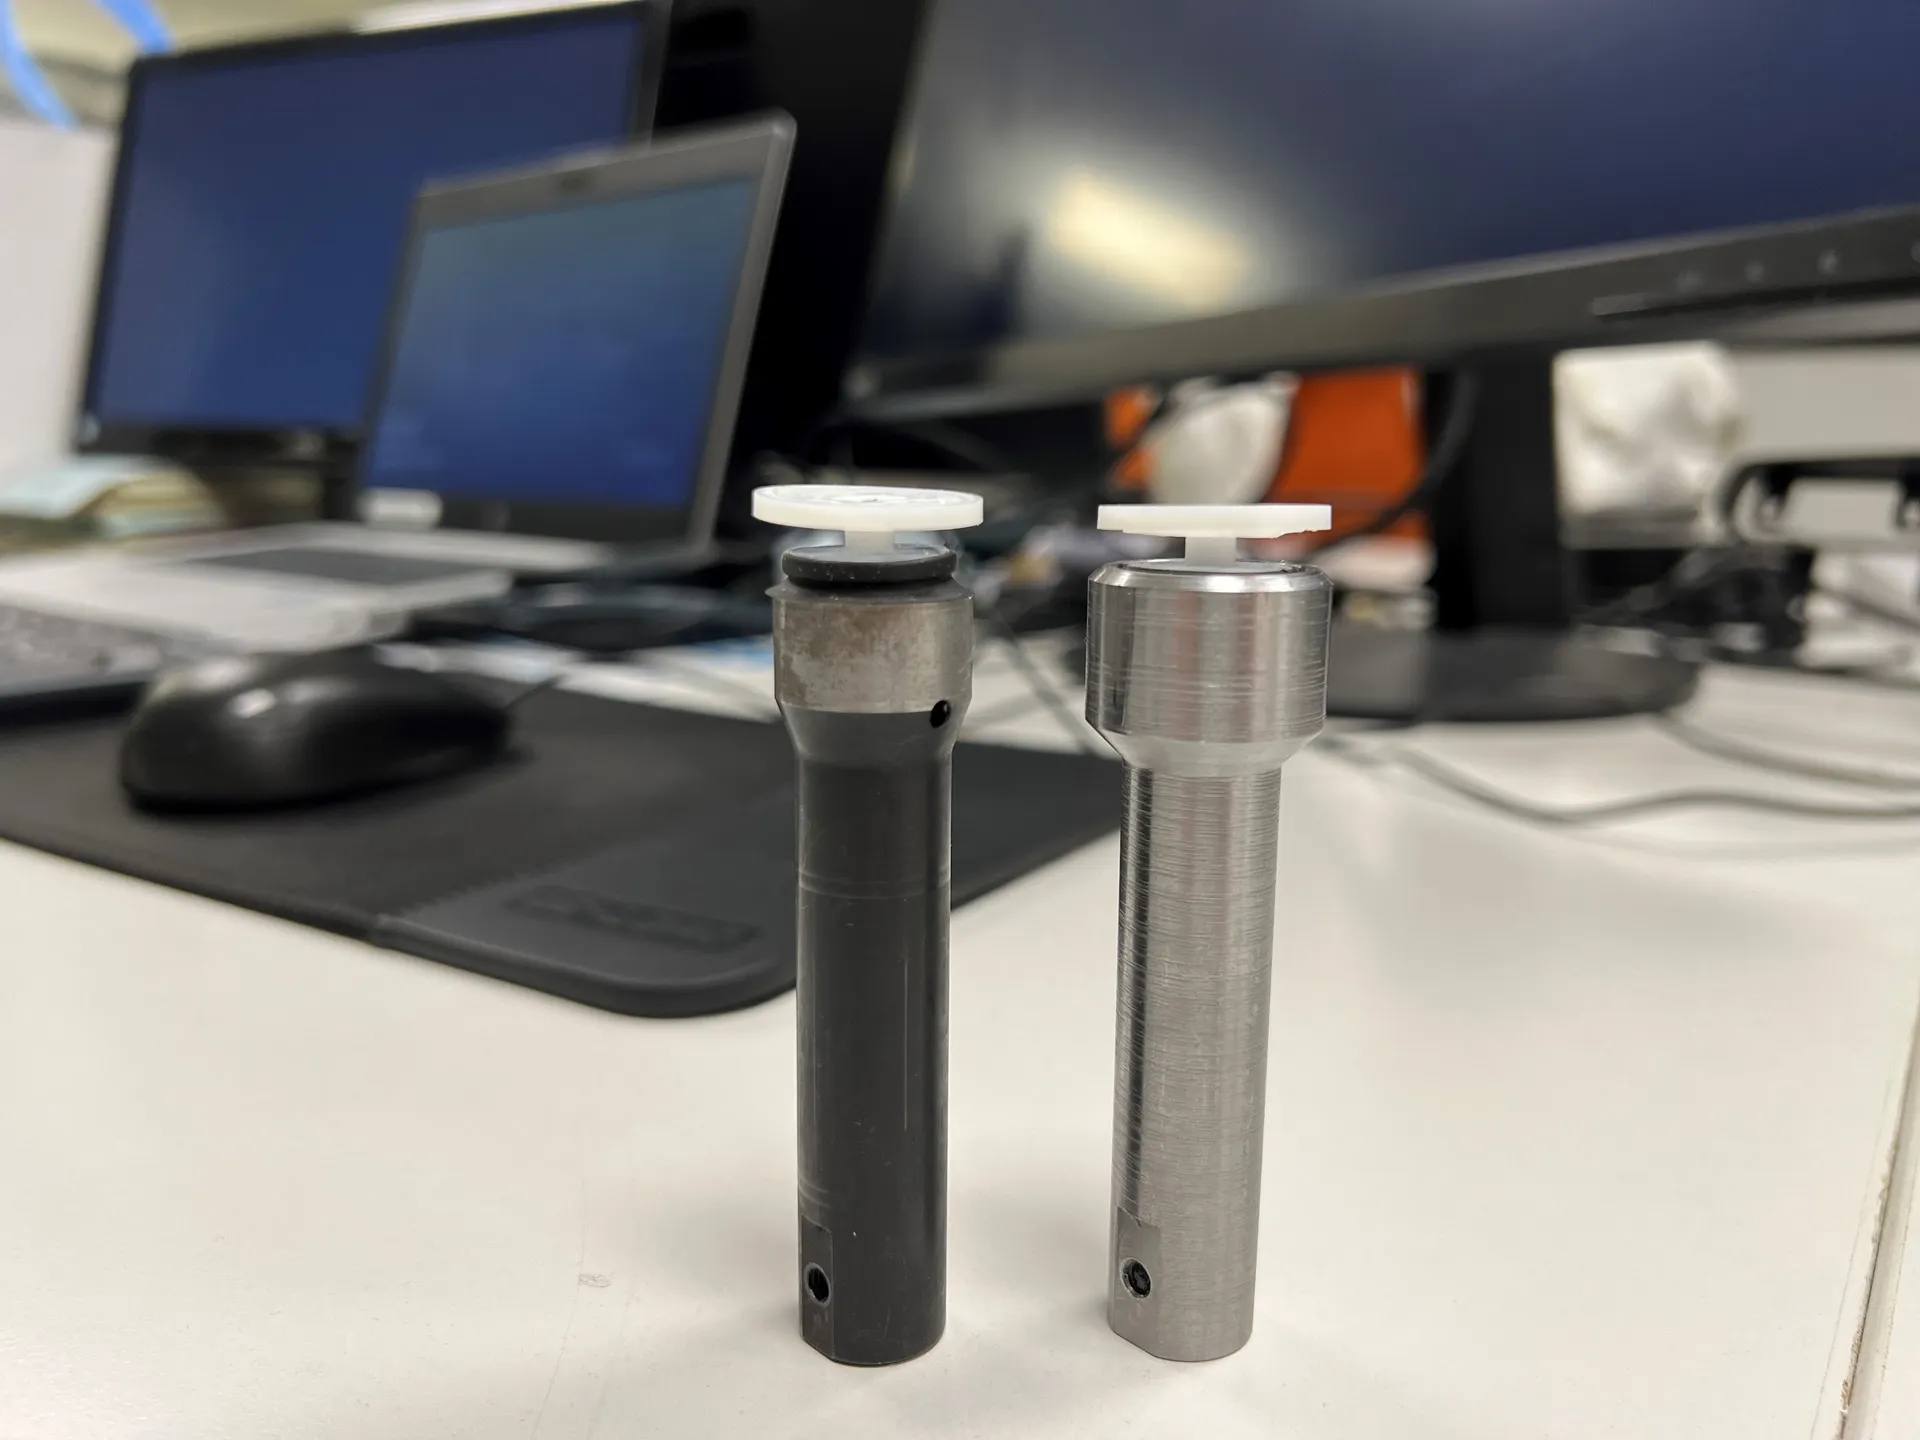
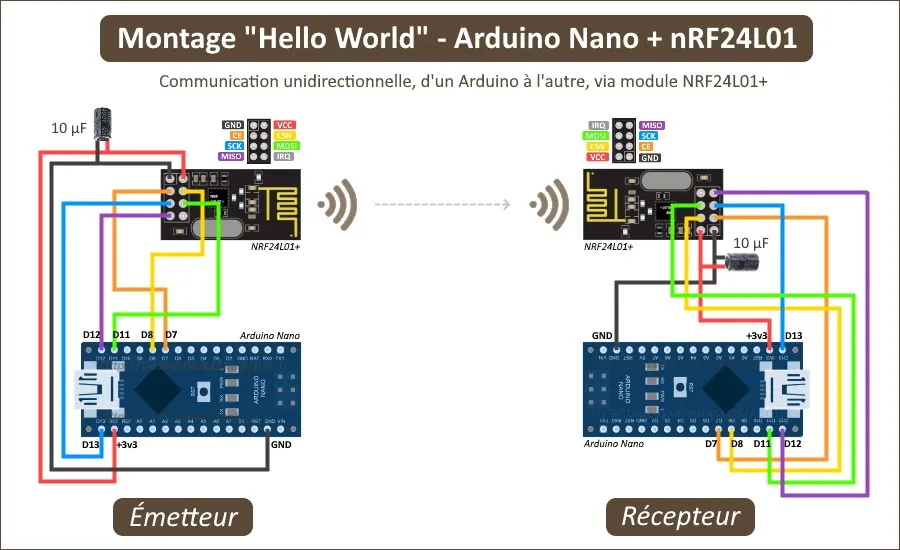
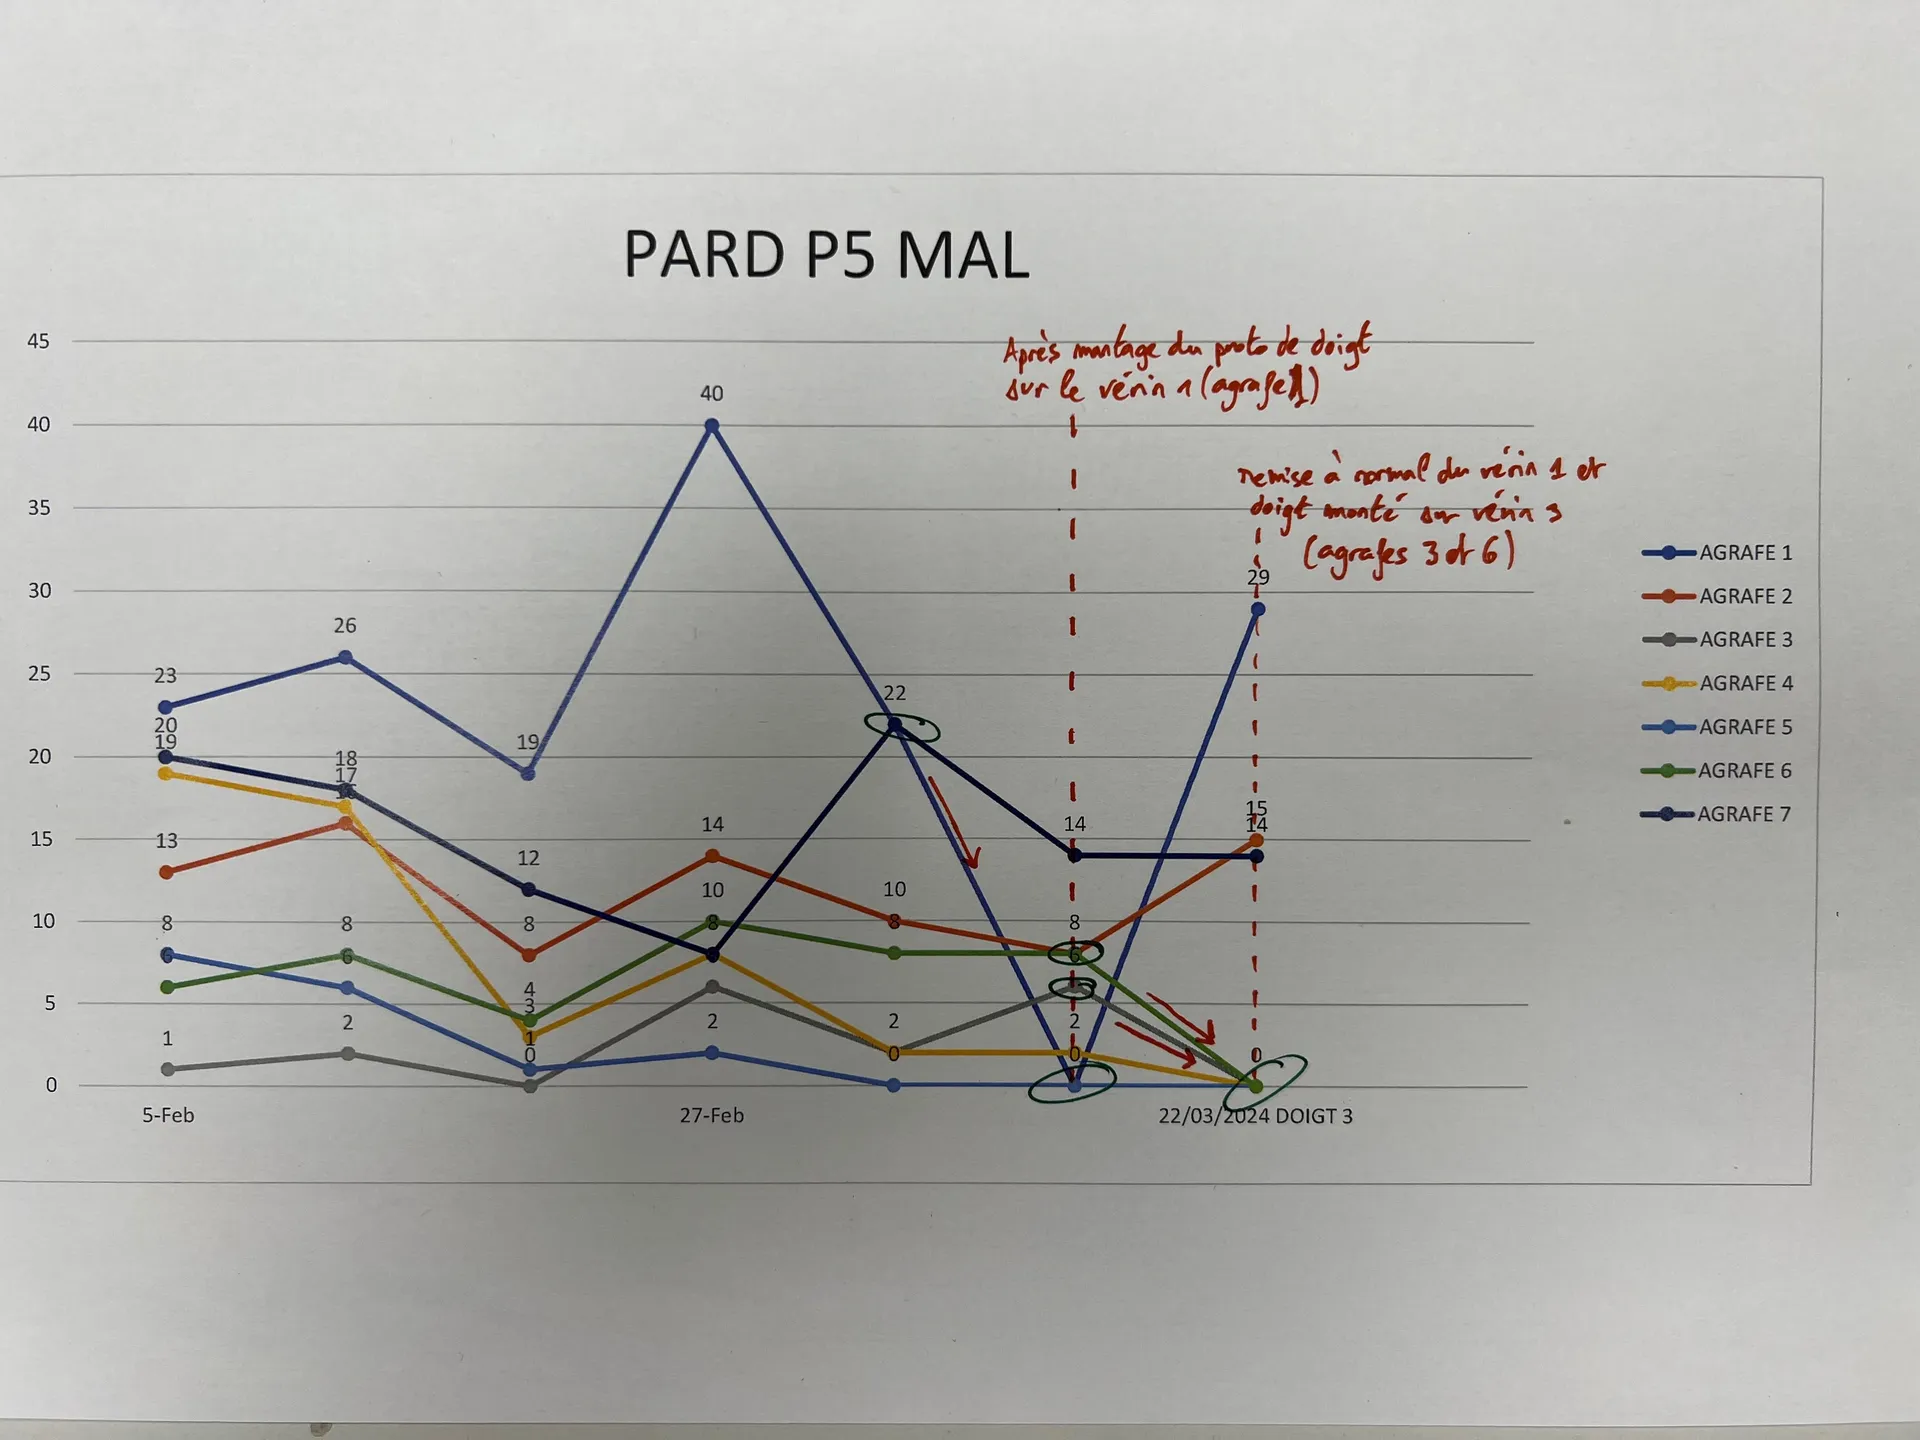
Ran the statistical analysis of fastening defects and insertion forces (14–21 N), designed a new gripper finger in PTC Creo with a precision-machined internal chamfer to mechanically compensate positioning error, and developed an embedded IoT monitoring system (Arduino Nano, MPU-6050, NRF24L01) with MATLAB-based fault detection to validate assembly quality in real time.
Results
100% success rate during industrial validation and deployment across multiple production workstations; received the 'Improvement Idea of the Month' award.